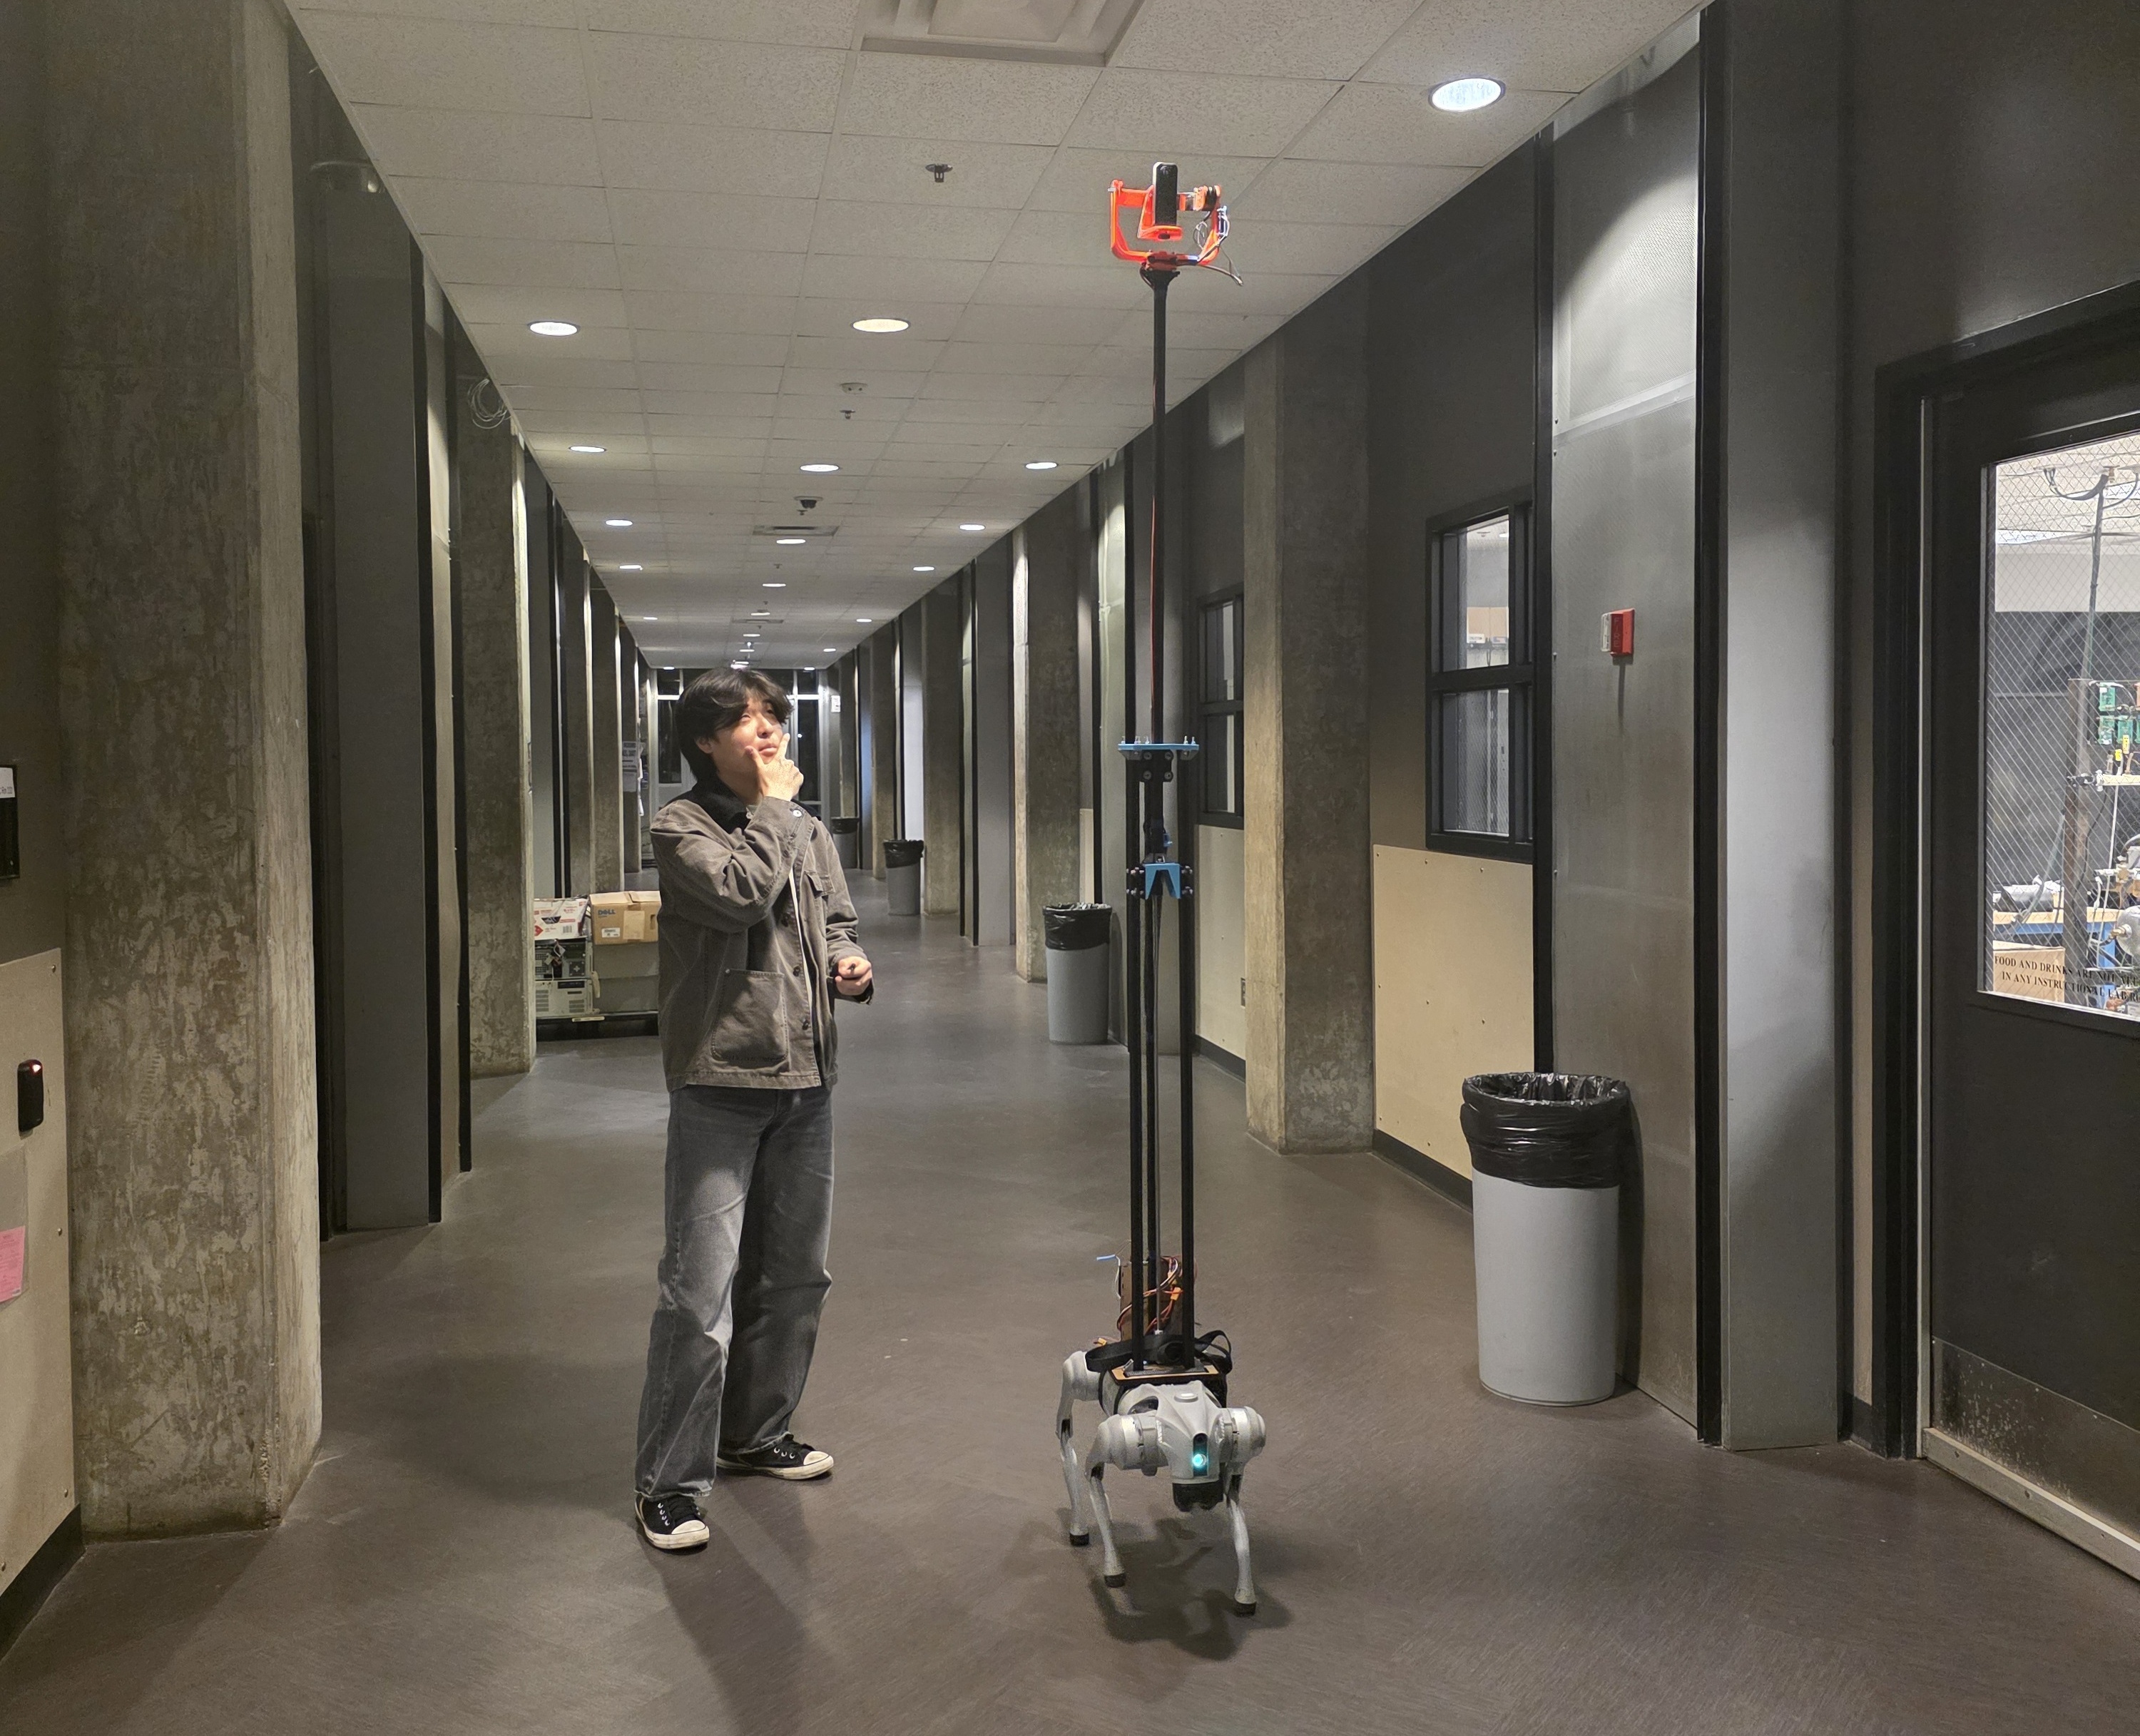
Team capstone · Aug–Dec 2025
Stabilized camera rig
A height-adjustable camera payload developed by our capstone team for a quadruped robot. My contributions included concept selection, gimbal design and drawings, and structural analysis.
Personal and team projects in mechanical design, UAV development, robotics, and systems integration.
Work in progress. I'm still updating this portfolio. Some projects are not yet included or fully described.
A height-adjustable camera payload developed by our capstone team for a quadruped robot. My contributions included concept selection, gimbal design and drawings, and structural analysis.
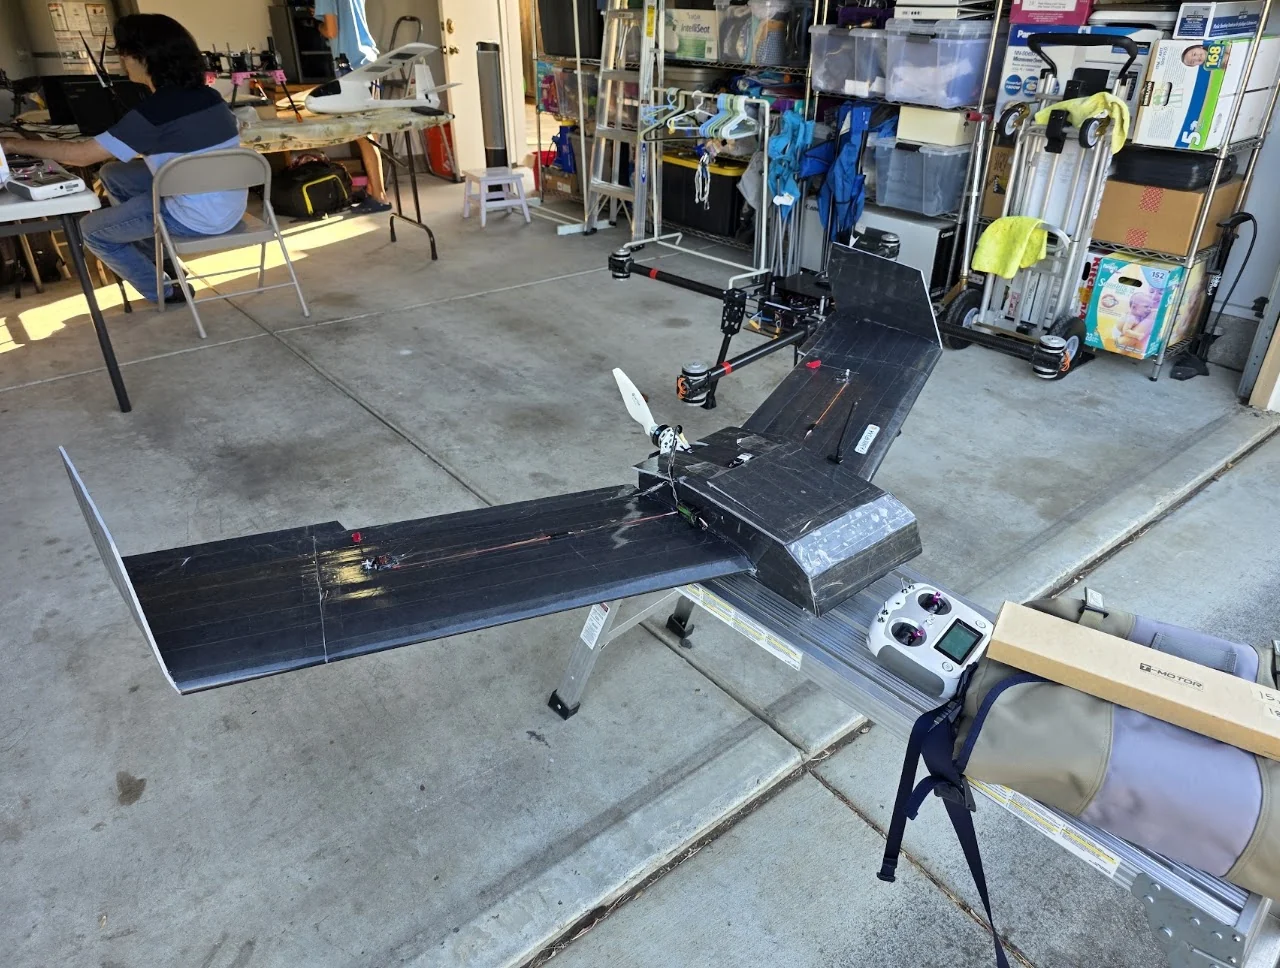
Independent fixed-wing UAV development, including airframe fabrication, custom landing gear, Pixhawk/PX4 integration, and flight testing.
UAV subsystem integration, troubleshooting, and configuration documentation, alongside a Python tool I developed to estimate flight time and range.
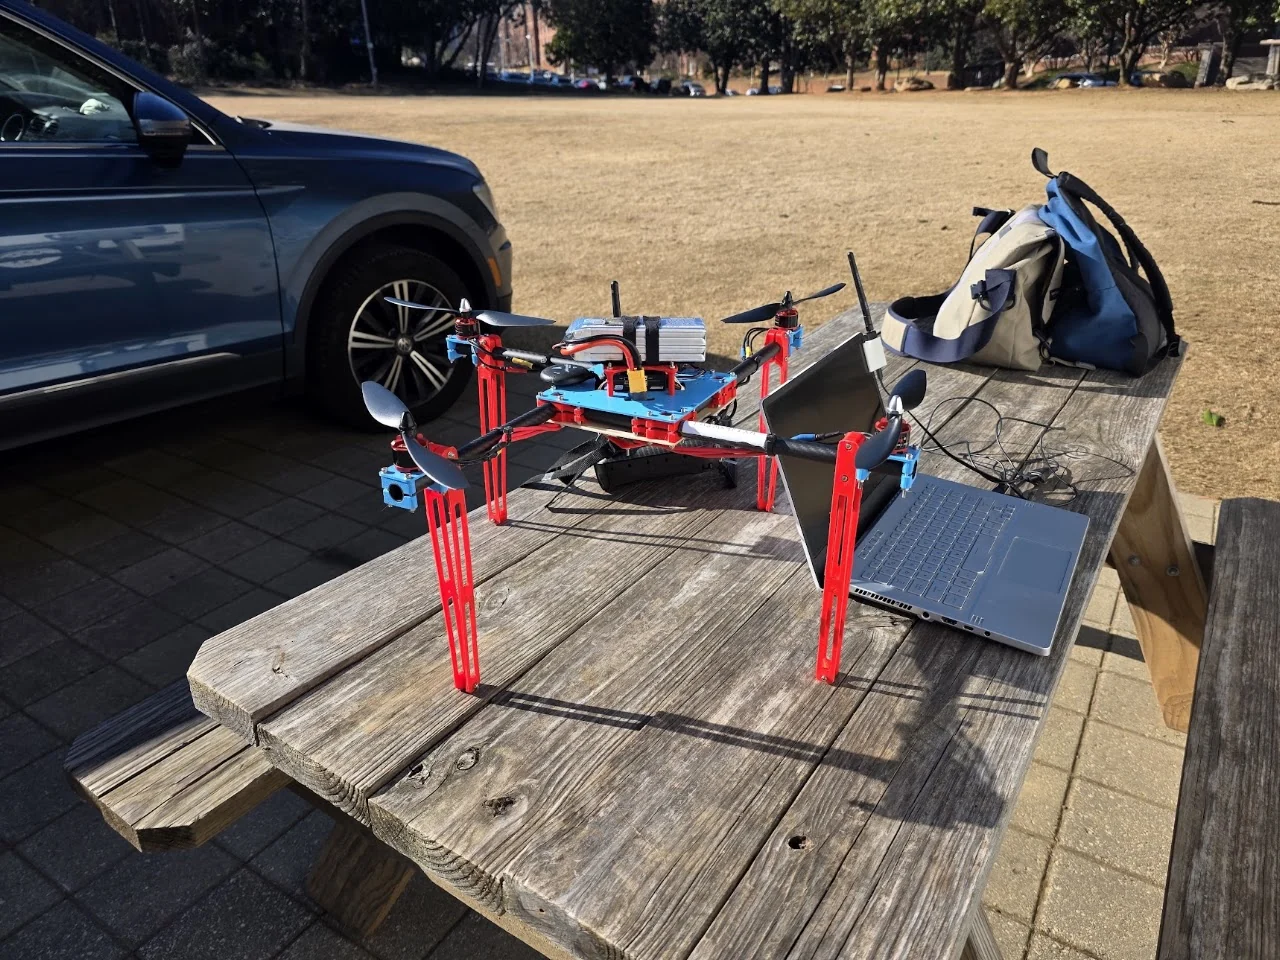
A custom quadcopter with modular printed components and tube arms. I designed the frame, integrated the electronics, and configured PX4.
Three documented configurations trace the development of my survey aircraft and its landing gear. See the aircraft progression →
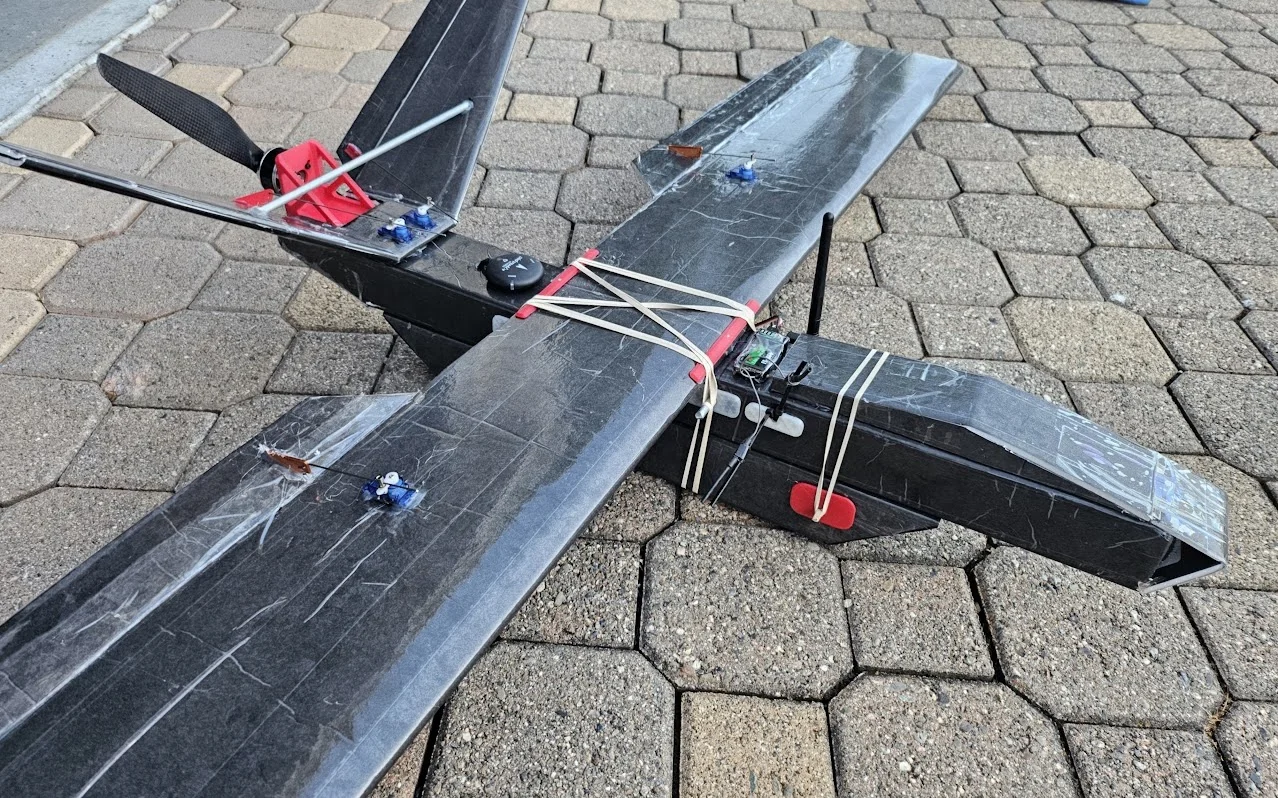
I used Onshape to develop the airframe layout and custom suspension landing gear, then fabricated the foamboard structure and integrated the autopilot.
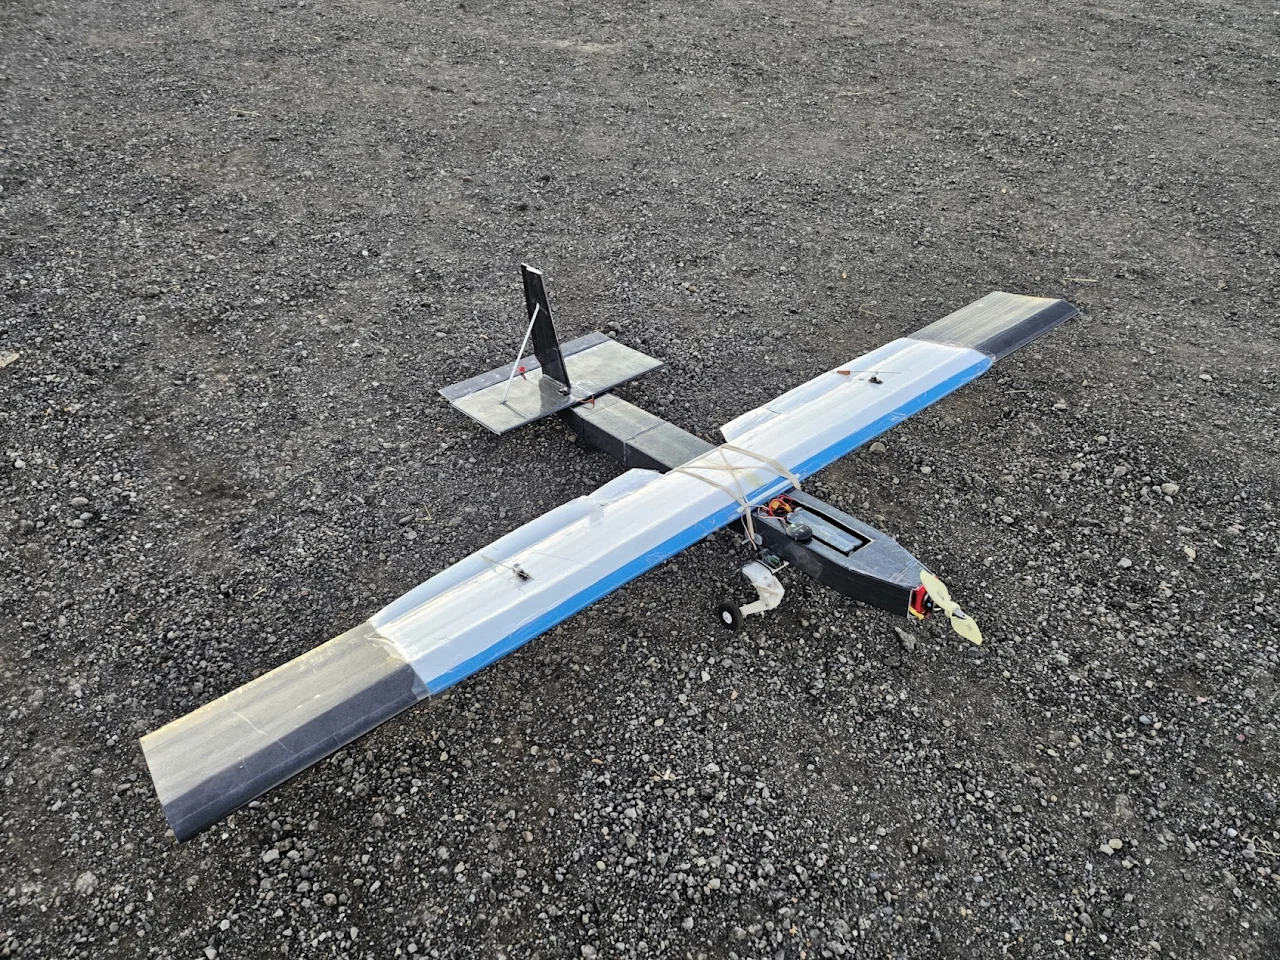
I revised the tail configuration, increased wing area, and added a servo-steered tailwheel to address control authority, wing loading, and propeller clearance.
High cruise-throttle demand on the preceding aircraft led me to explore a flying-wing configuration with carbon-fiber reinforcement.
Additional work in competition robotics, manufacturing, and aircraft restoration.
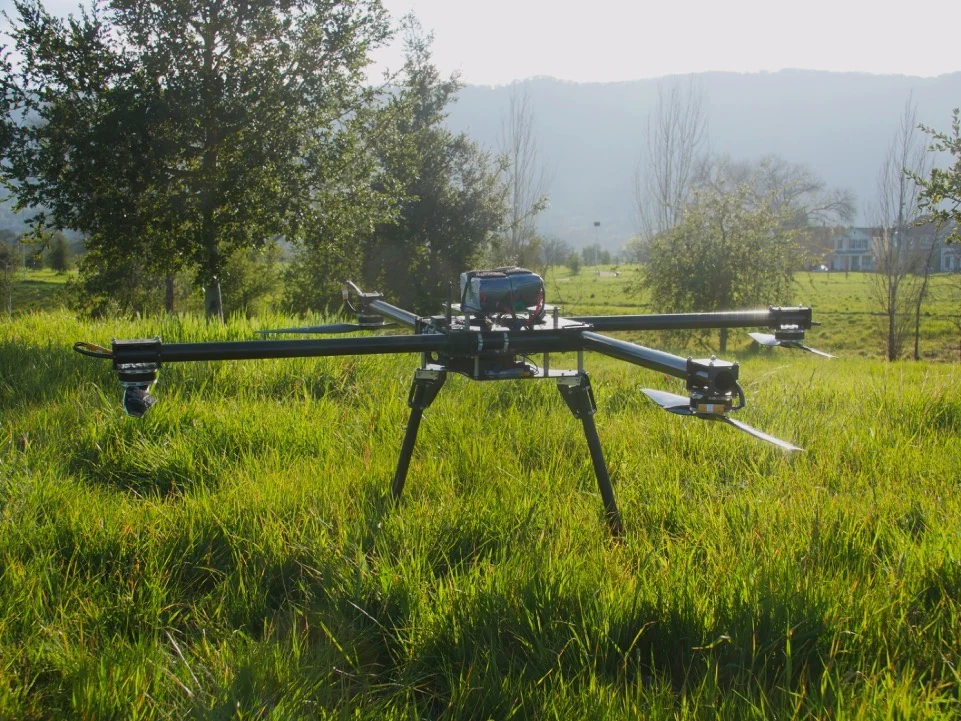
I contributed custom frame design and fabrication using carbon-fiber plates and printed mounting and landing components. The team aircraft included ground-vehicle deployment capability.
Our team placed 2nd overall in the 2022 AUVSI SUAS international collegiate competition. I also helped author the team's technical design paper.
Technical design paper (PDF) ↗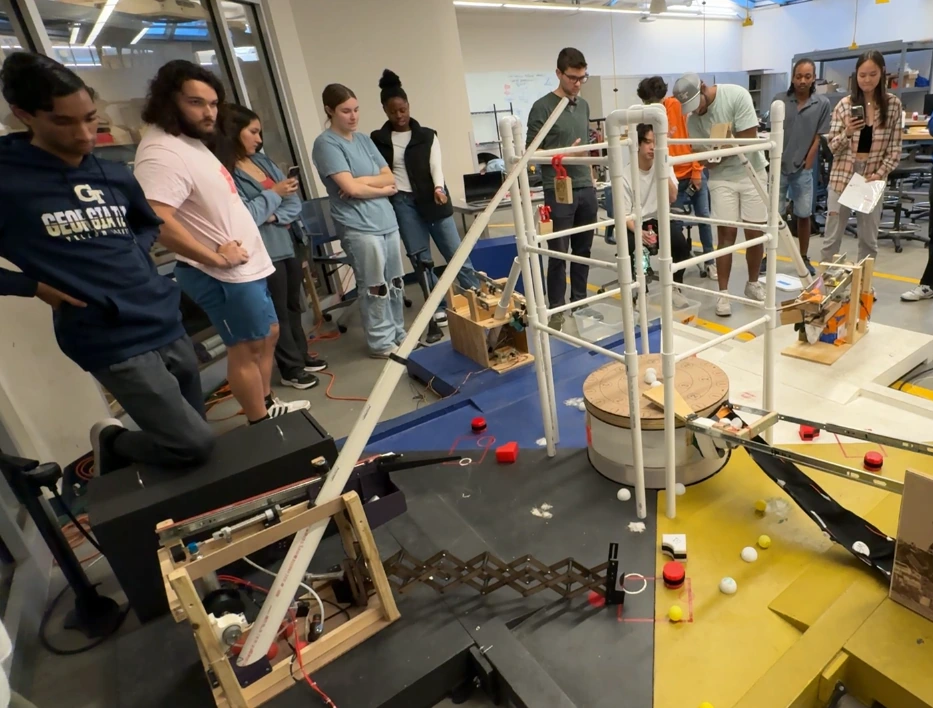
My work on our competition robot included mechanism CAD, fabrication, Arduino programming, and actuator integration for its lift and retrieval mechanisms.
View Mind-inator →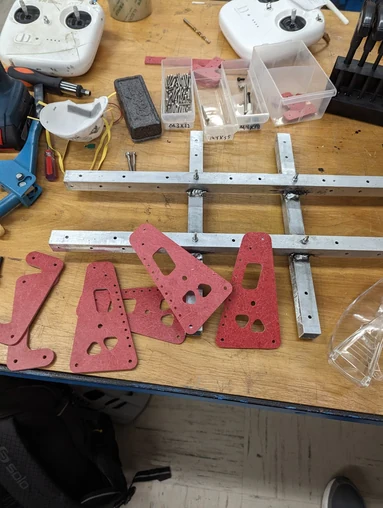
I designed, machined, and assembled fiberglass mounting plates that connected armor to our team’s competition robot chassis.
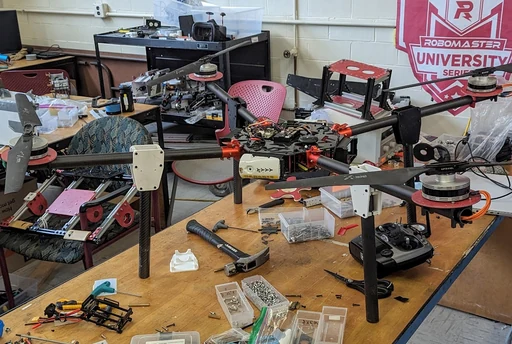
I contributed to the restoration of a largely disassembled quadcopter through SolidWorks motor and landing-gear mount design, PX4 configuration, and QGroundControl setup.
For project questions or engineering opportunities, get in touch.
Get in touch →